Research
Numerical Optimization
Research Description Our research in this area develops numerical optimization methods for engineering problems involving nonlinear dynamics, nonconvex constraints, and mixed-type variables. We combine learning-based modeling with algorithms that exploit mathematical structure to make challenging problems more computationally manageable. Our work spans Koopman-operator-based optimal control, quadratically constrained quadratic programming, and rank-constrained semidefinite programming. Across these directions, we emphasize computational efficiency, theoretical analysis, and practical algorithms that support engineering design and autonomous decision-making.
Autonomy of Reconfigurable Space Robots
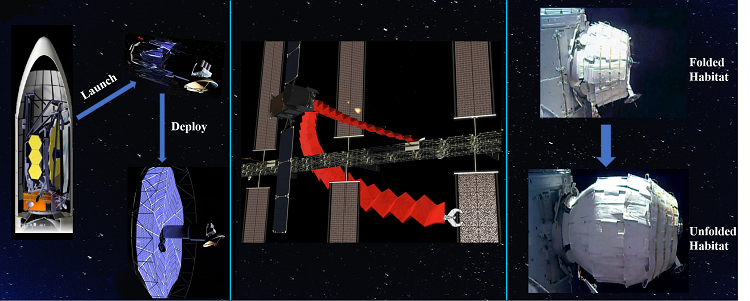
Research Description Our research advances the autonomy of origami-inspired space robots by integrating structural design, dynamic modeling, and feedback control. We exploit the compact storage and shape-changing capabilities of origami to develop systems that can adapt their geometry and functionality to different mission requirements. Our work spans control-oriented models of folding and unfolding, optimization-based design of multifunctional origami patterns, and deployable mechanisms for space debris collection. By connecting mathematical analysis with simulation and laboratory prototyping, we aim to move beyond passive deployable structures toward robotic systems capable of controlled reconfiguration for future space operations..
Sustainable Operation of Autonomous Systems
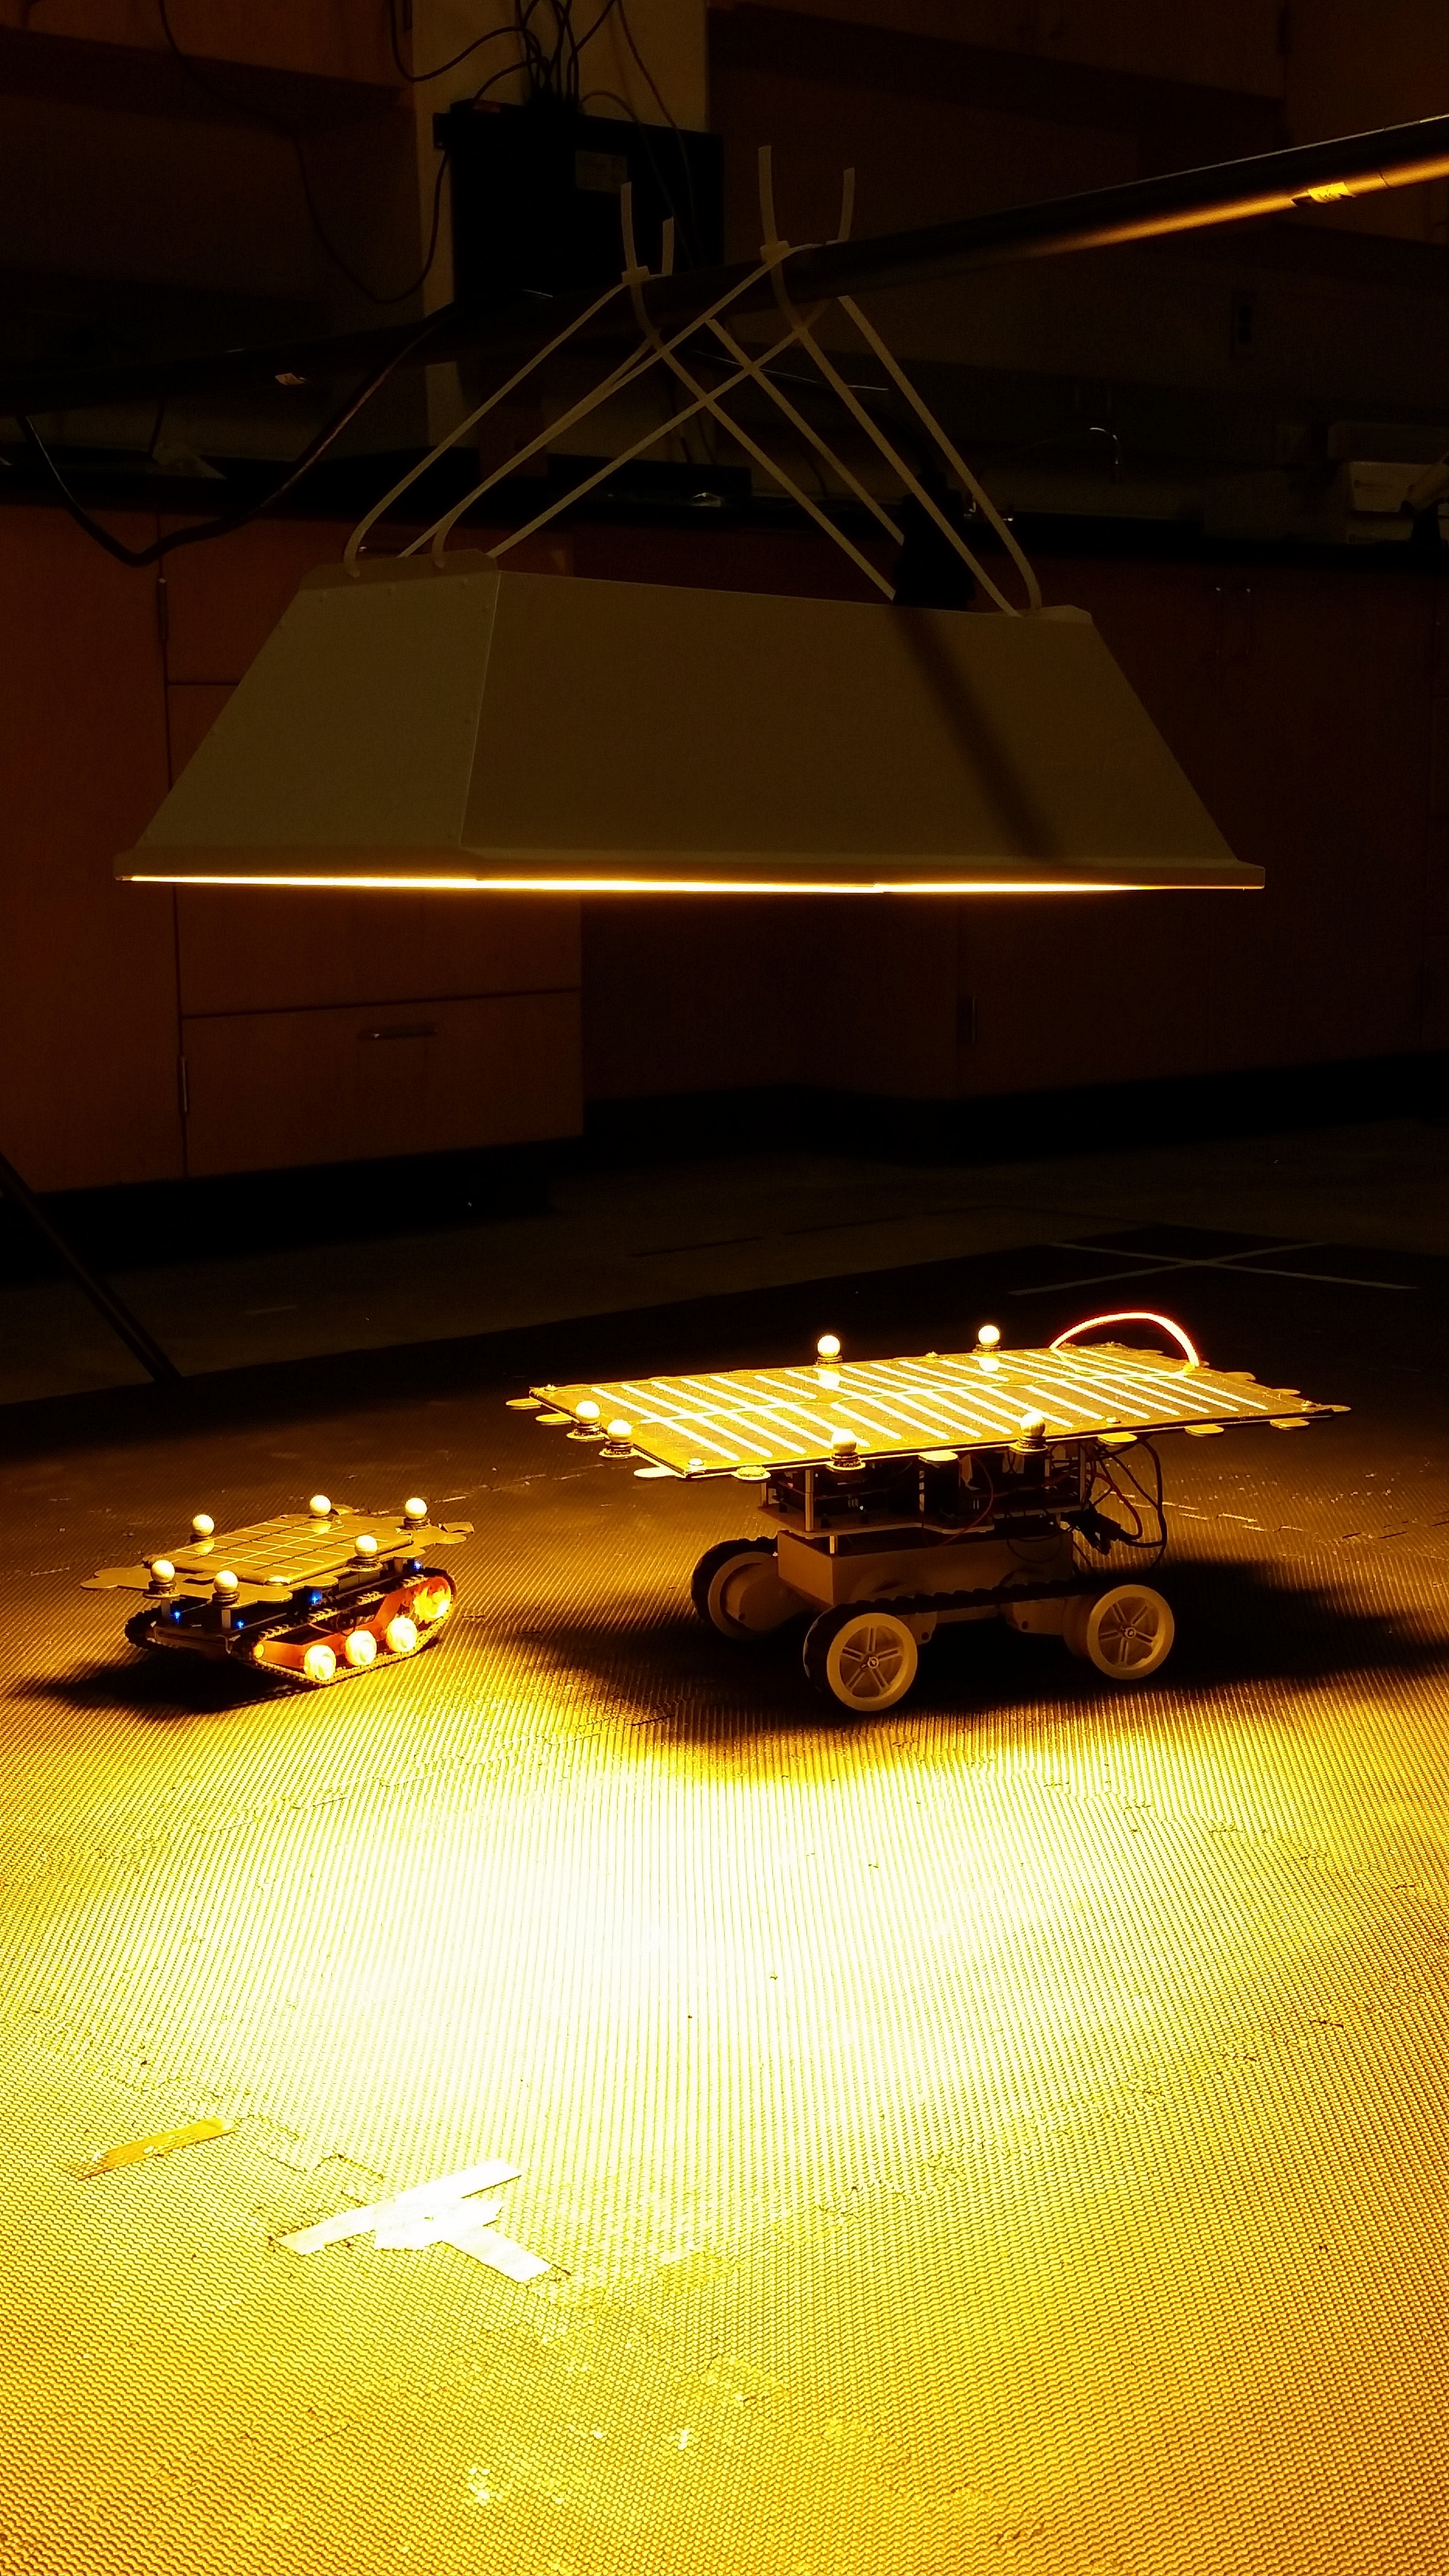
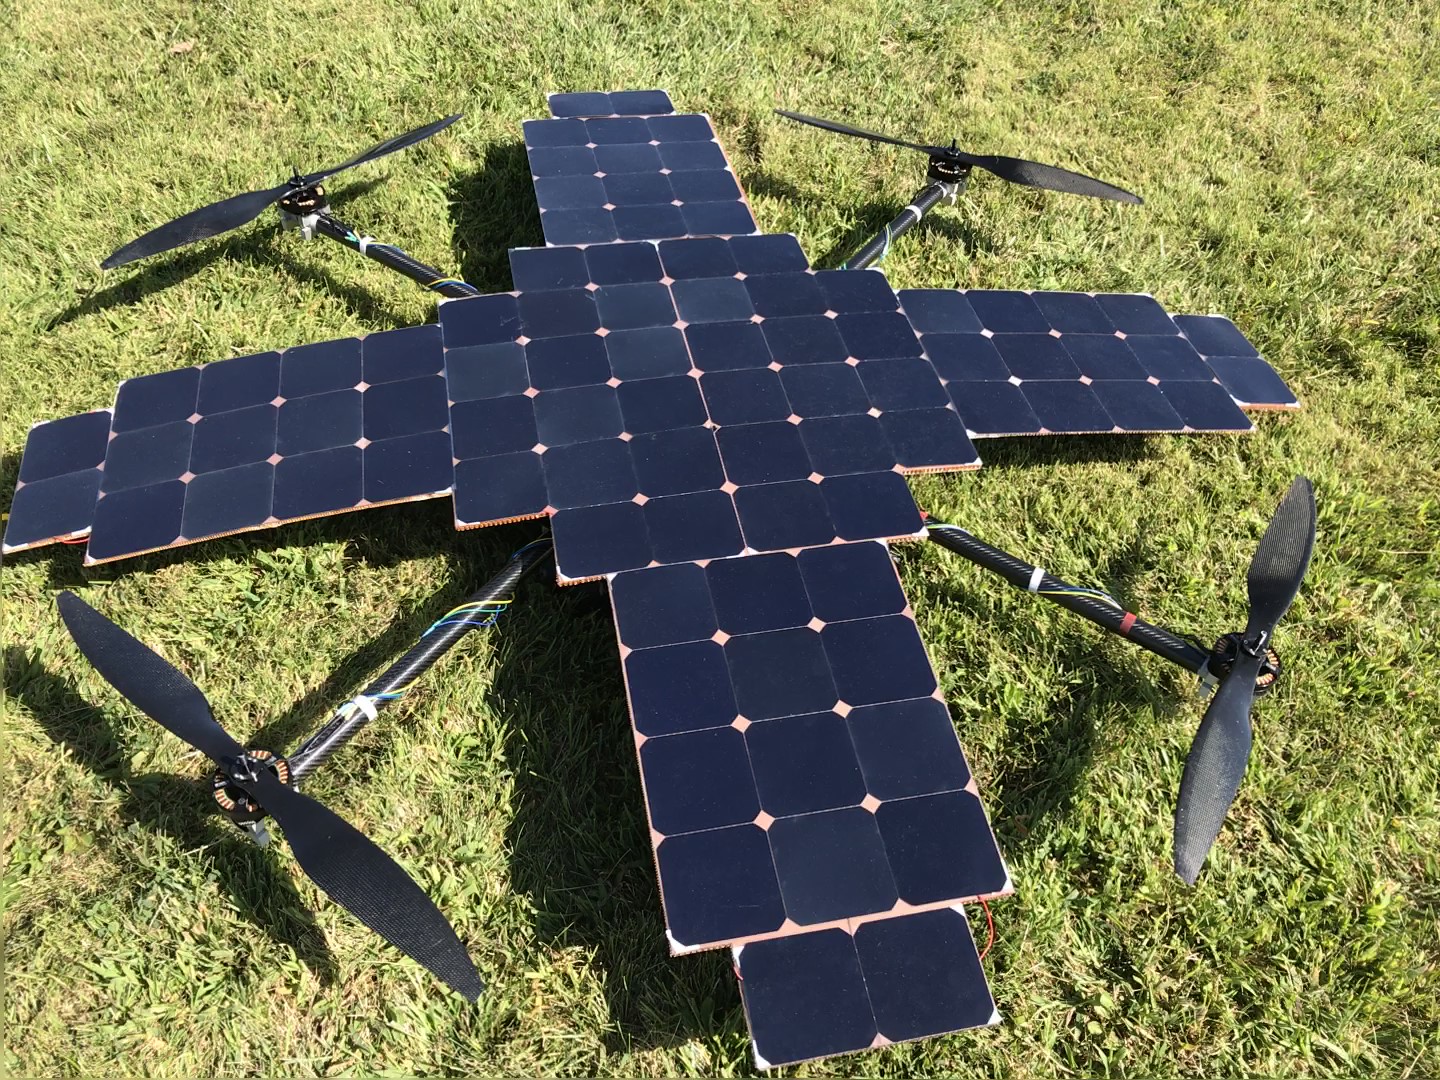
Research Description Our research advances the long-term operation of unmanned aerial vehicles (UAVs) and ground vehicles (UGVs) by integrating energy-aware design, renewable energy harvesting, and autonomous energy replenishment. We develop systems and algorithms that coordinate how robots acquire and use energy while meeting motion and mission requirements. Our work spans in-air battery swapping, solar-powered unmanned aerial vehicles, and integrated power management and mission planning for ground robots. Through modeling, optimization, control, and experimental validation, we aim to extend operational endurance, reduce energy-related mission interruptions, and enable autonomous systems to accomplish sustained missions beyond the limits of onboard energy storage. [Details]

Human-Mars Entry, Powered Descent and Landing Guidance
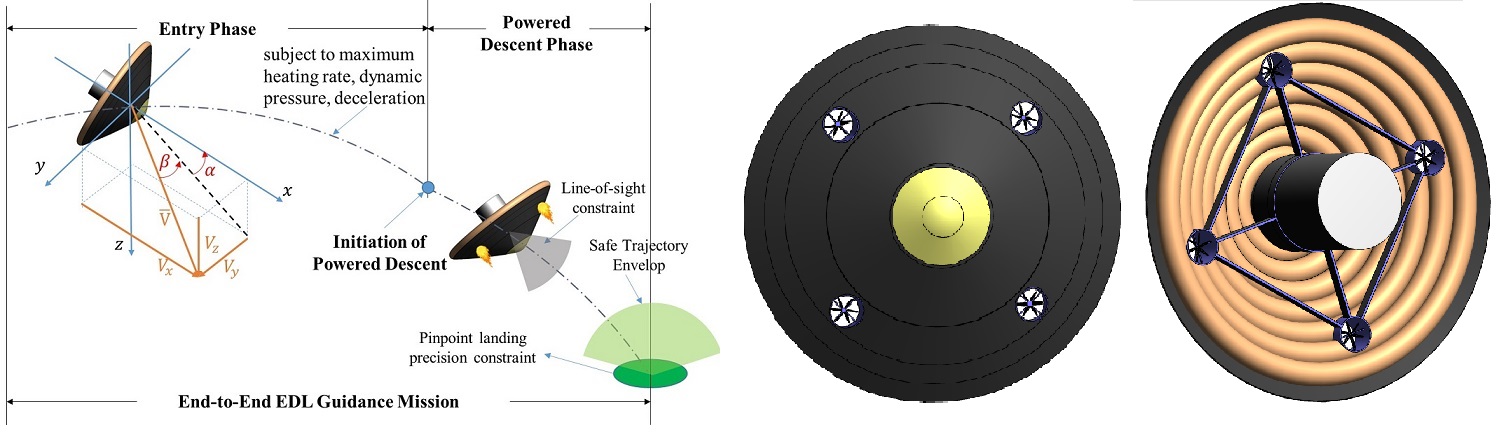
Research Description A human-Mars mission requires the delivery of a high payload from the entry interface at supersonic speed to a preflight-designated surface location at near-zero speed with pinpoint precision. The supersonic retro-propulsion system to decelerate the vehicle at supersonic speed consumes significant amount of propellant. It becomes a challenging task to achieve high precision landing while minimizing fuel consumption during descent phase. Our research develops computationally efficient guidance methods for precise and fuel-efficient landing of human-scale vehicles on Mars. We integrate optimal control theory, numerical optimization, and machine learning to address the coupled challenges of atmospheric entry, powered descent, and landing (EDL). Across these directions, we aim to generate guidance commands that account for vehicle dynamics, operational constraints, and limited propellant, supporting increasingly autonomous landing capabilities for future Mars exploration. [Details]

Space Object Motion Estimation and Autonomy of Proximity Operations
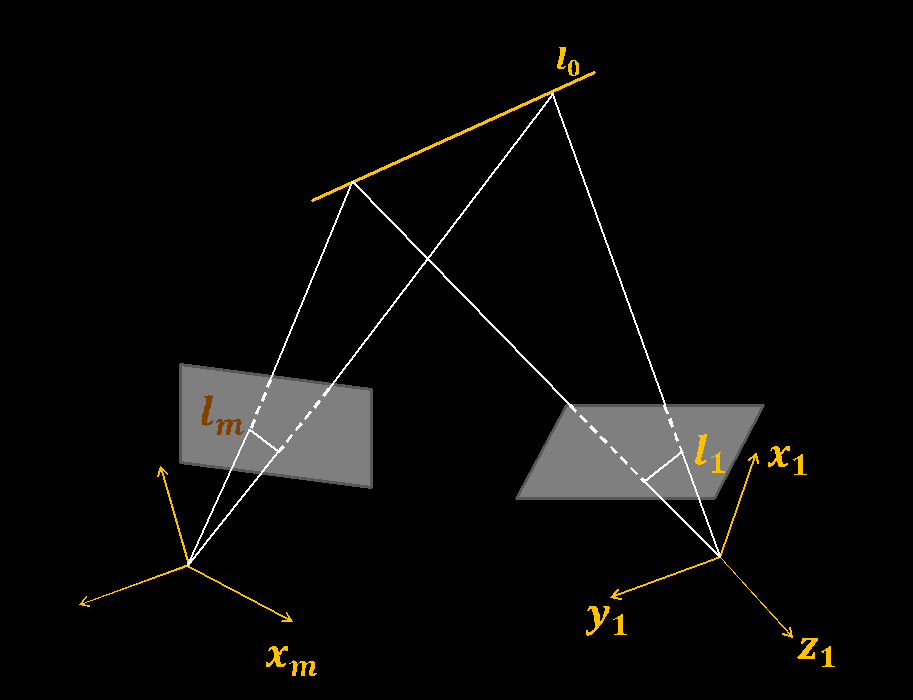
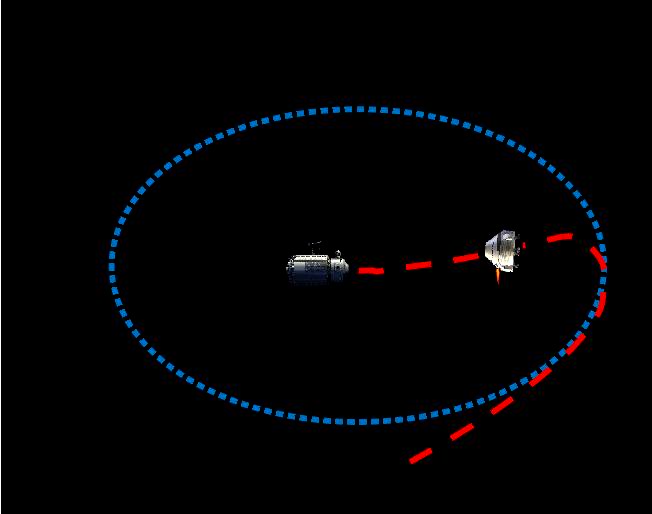
Research Description A number of space missions depend on accurate estimation of the relative motion of space objects and high autonomy of proximity operations. Examples include rendezvous, formation flight, debris avoidance and asteroid capture. However, for space objects flying with high translational and rotational speed, it is challenging, yet essential, to estimate and control their relative motion when realizing autonomous/semiautonomous operations. In this project, by establishing a dual quaternion based new modeling paradigm, our goal is to develop an integrated motion estimation and optimal control strategy to advance the autonomy level of proximity operations. [Details]
Dynamic Network Design, Identification, and Control
Research Description A wide range of networks are evolving along time, which makes it challenging to generate time-critical control strategies that depend on understanding of the interaction relationships and models describing time behaviors of controllable entities. This work aims to develop computational approaches to interpret and regenerate structured data for design, identification, and control of dynamic networks. The unified method for data construction and analysis is expected to be applicable to a variety of network systems, ranging from sensors, multi-agent robotic, social, and biological systems. [Details]